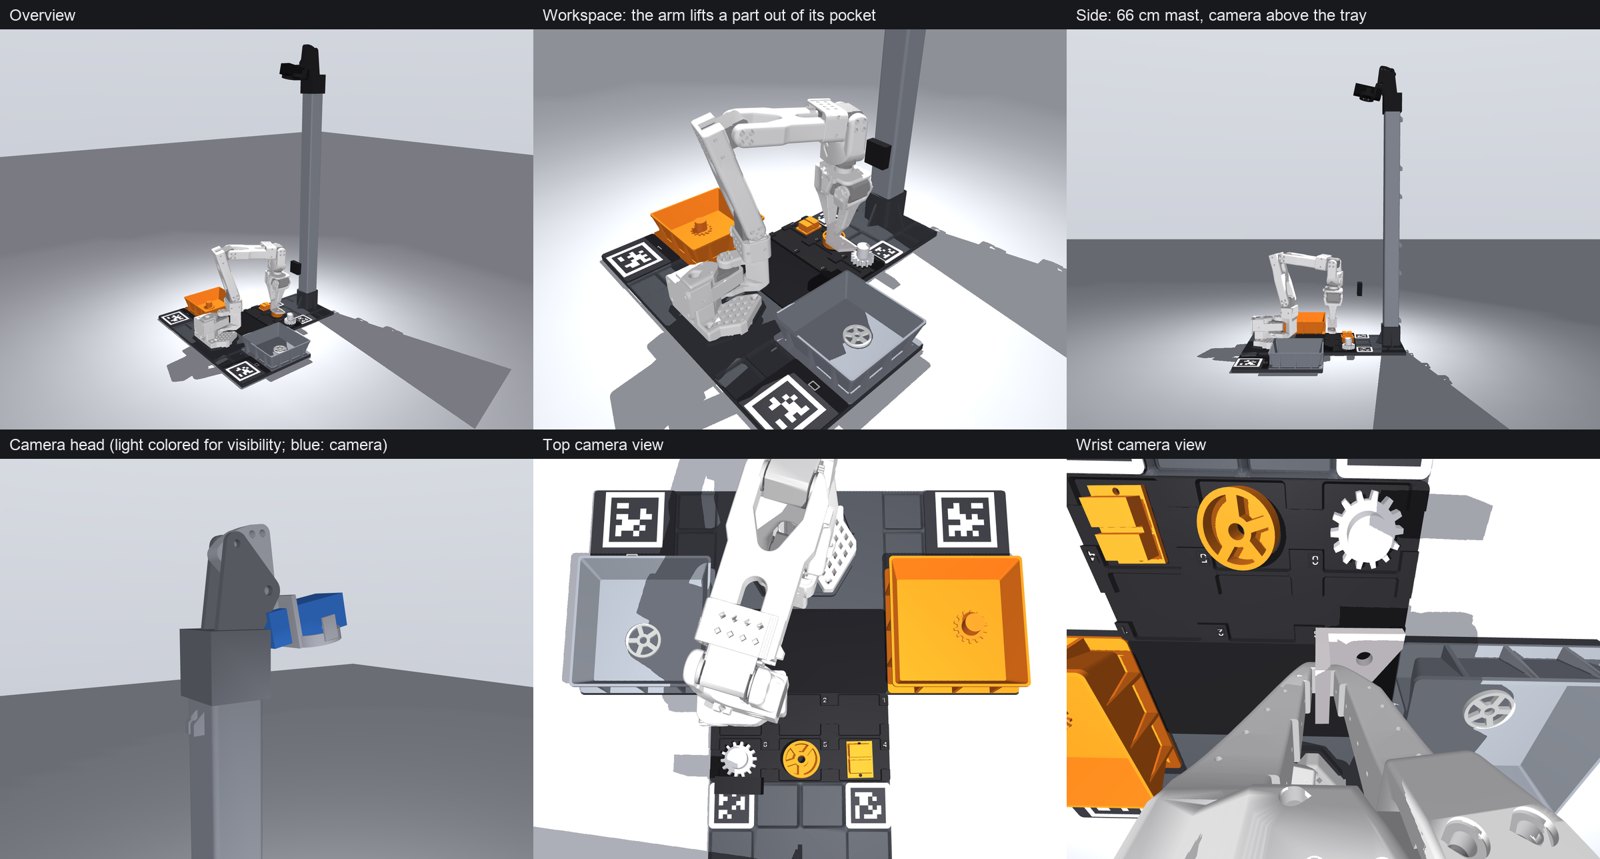
SO-101 zero to hero
From an empty desk to a robot arm that sorts parts on a spoken-style command, using a policy you trained on data you
recorded. Eight steps. Each one is a few plain lerobot-* commands; the page behind it explains what the command
does and what to watch for.
The task. A tray holds six 3D-printed parts. A camera above looks once and decides, per pocket, OK or REJECT. The arm is then told, one part at a time: "put the part from pocket 3 in the REJECT bin".
| Step | You do | You learn | |
|---|---|---|---|
| 1 | Build the cell | Print, assemble, mount two cameras | Why the scene must not move |
| 2 | Set up the arm | Install, calibrate, teleoperate | Leader/follower, joint space |
| 3 | Inspect the tray | flywheel-inspect |
Classic vision vs a VLM, grounding |
| 4 | Record | scripts/record.sh 1 ok × 12 blocks |
What a demonstration dataset is |
| 5 | Data quality | Follow the checklist while recording | Why policies fail: it is the data |
| 6 | Review and upload | Watch, delete bad episodes, push | The LeRobot dataset format |
| 7 | Train | scripts/train.sh (SmolVLA, rented GPU) |
VLA, action chunks, flow matching |
| 8 | Run and improve | scripts/rollout.sh 3 ok, score, correct |
Evaluation, DAgger, the data flywheel |
Then: what to try next (Cosmos 3, sim-to-real transfer, grounding models, RL) and the concepts in one page.
What you need
- SO-101 leader + follower arm, two USB webcams (one above, one on the gripper)
- A 3D printer for the cell, or any tray and two boxes you fix to the desk
- A Mac or Linux laptop for recording; a rented GPU for training (about 4 h of an A100, roughly $10)
- A free Hugging Face account: the dataset and the policy live there
Today, in order
scripts/teleop.sh --cams      # 1. both cameras see what they should
uv run flywheel-inspect       # 2. the top camera reads the tray (run inside python/)
scripts/record.sh 1 ok        # 3. first block of 10 episodes
scripts/status.sh             # 4. what is left; repeat until 120
scripts/train.sh              # 5. SmolVLA on a rented GPU
scripts/rollout.sh 1 ok       # 6. the policy moves the arm